Axial-flux motors and frameless torque motors are the two core technical routes for humanoid robot joint drive today; they differ markedly in topology, performance and industrialization progress, and respectively suit different joint needs and development stages.
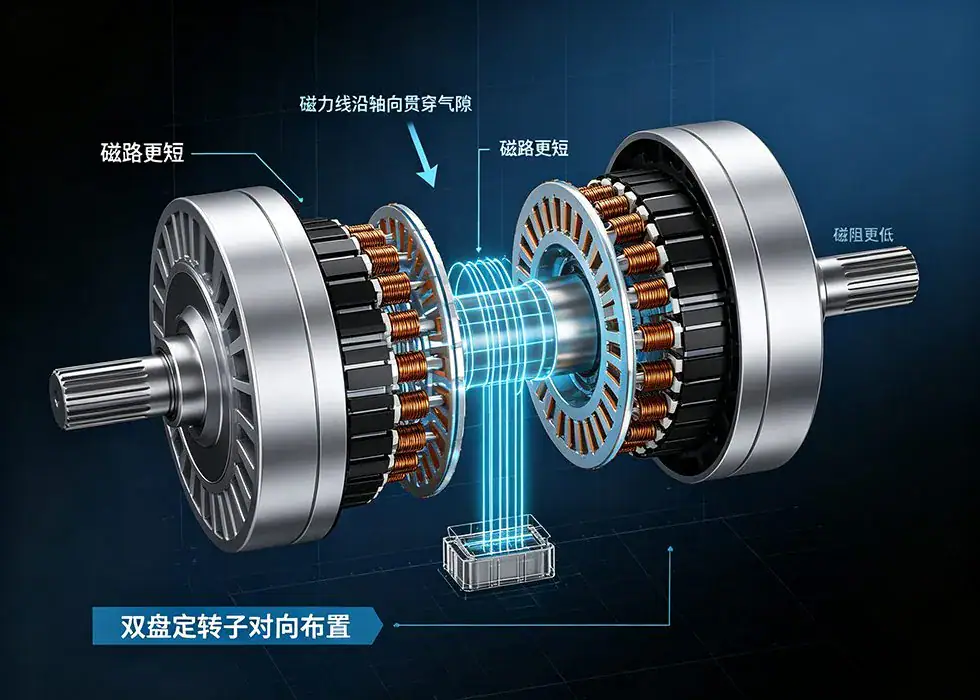
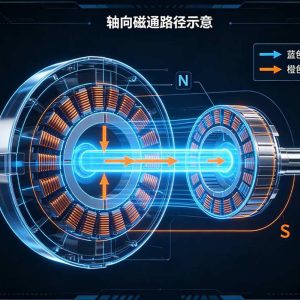
Magnetic Circuit Principle of Axial-Flux Motor
In terms of topology, the flux direction of an axial-flux motor is parallel to the motor shaft; the stator and rotor are arranged as two or more opposing discs with the air-gap field distributed axially, shortening the magnetic path and reducing reluctance losses compared with a conventional radial motor. The frameless torque motor omits the housing, bearings and output shaft of a conventional motor, keeping only the stator and rotor assemblies, and can be embedded directly inside a joint and integrated with the reducer; its working principle resembles a direct-drive motor but with better torque density.
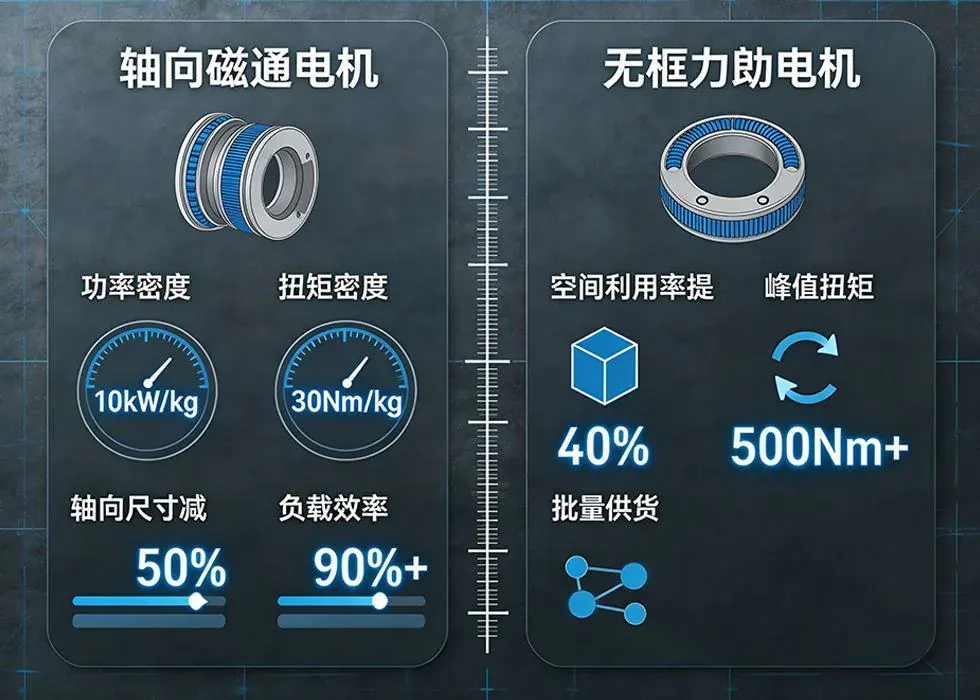
Visual Comparison of Performance Indicators for Two Types of Motors
At the performance level, the core advantage of the axial-flux motor is ultra-high power density and a flat structure. Its power density can reach 10kW/kg and its torque density 30Nm/kg, its axial size is reduced by 50% versus conventional solutions, and its efficiency is above 90% across a 20%-95% load range, making it suitable for the frequent start-stop conditions of humanoid robots and better fitting the space requirements of built-in joints. The advantages of the frameless torque motor centre on high integration and industrial maturity: it is designed in one piece with the joint structure, raising space utilization by over 40% and enabling zero-backlash transmission with peak torque above 500Nm; meanwhile its supply chain is well developed and batch supply has been achieved, making it the current mainstream deployment solution.
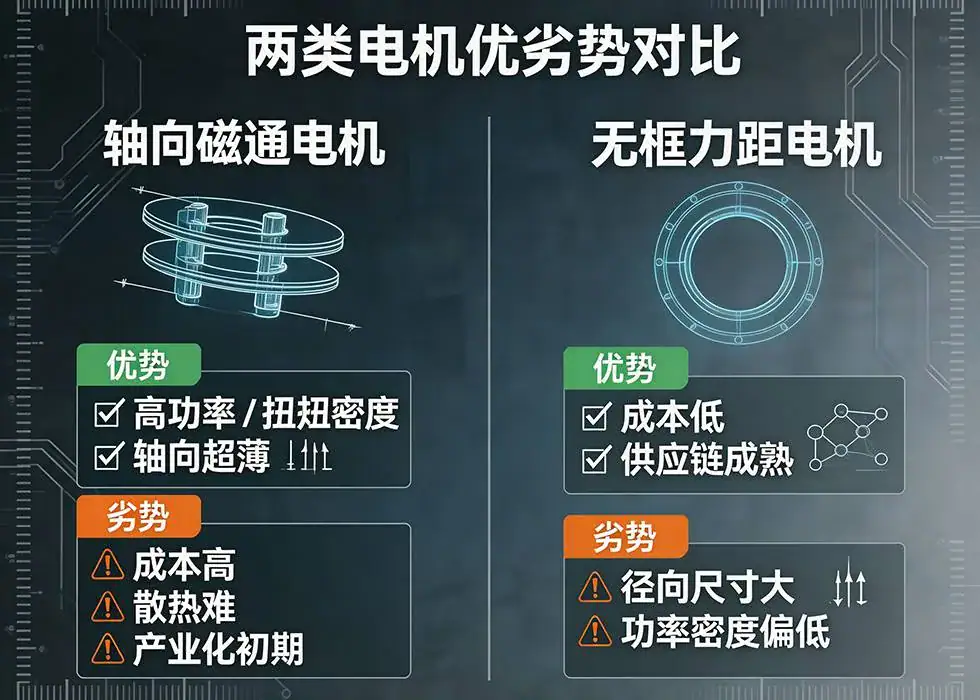
Advantage Comparison Chart
Comparing key indicators, the axial-flux motor leads in power density, torque density and axial size, but costs more and is harder to cool, and its industrialization is still at an early stage; the frameless torque motor has low mass-production cost and a mature supply chain, but its radial size is relatively large and its power density is relatively low.
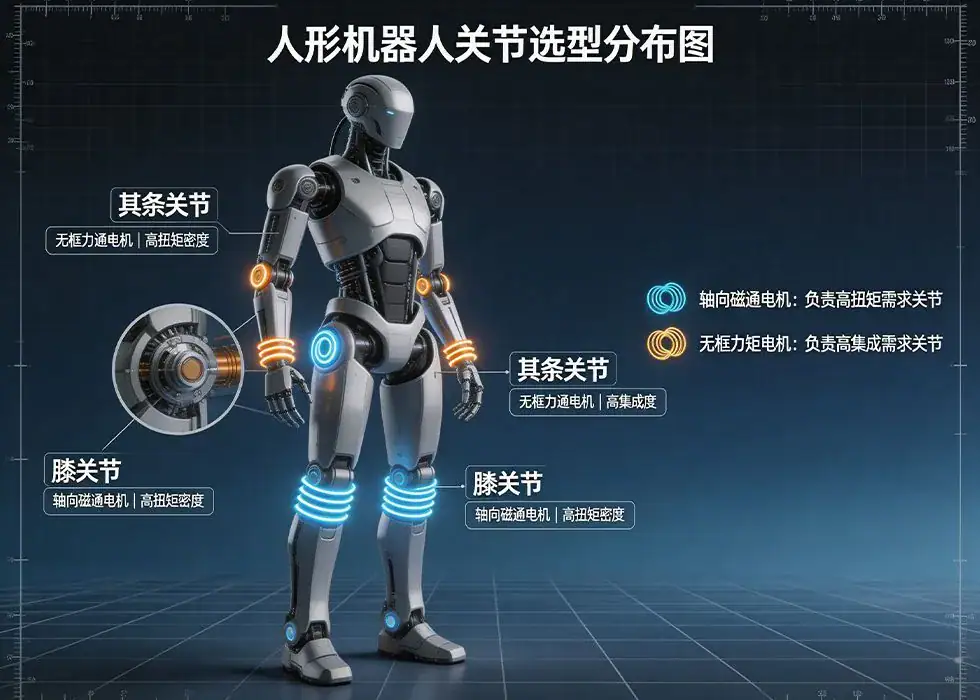
Joint Selection Distribution Diagram of Humanoid Robots
In terms of selection logic, load-bearing lower-limb joints such as the hip and knee better suit the high torque density of axial-flux motors. In the short term, frameless torque motors remain the market mainstream; in the medium and long term, axial flux is expected to form a differentiated replacement in high-torque lower-limb scenarios, and hybrid drive combining the two may also become the industry's endgame. Jiuju has mature technical accumulation in core processes such as stator-rotor magnetizing and precision assembly for both motor types, supporting precision control and mass-production rollout of joint motors and helping advance the industry's technology.
The shipping area outside the workshop was a hive of activity. After multiple rounds of full-machine commissioning, simulated mass-production validation, and factory quality inspection, a Jiuju DC motor automatic assembly line completed all factory-out procedures, was loaded onto trucks on schedule, and is about to depart for the customer's production base, helping the customer's project advance production implementation on plan.
High-performance NdFeB is indeed expensive, but an axial-flux motor's "cost per unit torque" does not lose out. It uses less magnet and copper material, and can even save the system a gearbox or battery capacity, making the overall BOM more cost-effective instead.
The stator winding is exposed on a flat disc, giving a short heat path so oil or water cooling can be applied directly; however, large-diameter flat seals are more prone to leakage under hot-cold cycling, demanding higher sealing quality.
A motor technology with superior torque density and power density — why is the mainstream market still dominated by radial motors? A breakdown from three angles: talent pool, industrial inertia, and production-line sunk cost.
 Jiuju Automation



 Spanish
 French
 German
 Hindi