The key to humanoid robots lies in their overall adaptability
When evaluating the quality of robot motors, one cannot rely solely on hardware specifications; high-performance motors that are not compatible with the overall system have no practical value. Excessively high rotational speeds in lower-limb motors can disrupt walking gait, while excessive torque in hand motors can not only damage objects being manipulated but also pose safety risks to users. Therefore, motor R&D must be developed in an integrated and coordinated manner with the robot’s body structure, electronic control system, and safety protection modules. At present, the three mainstream drive solutions in the industry all have inherent flaws: high-reduction-ratio flexible drives provide ample power but lack control precision and are prone to vibration during operation; elastic transmission, which incorporates elastic elements, offers greater shock resistance but sacrifices dynamic response speed; and low-reduction-ratio direct-drive transmission provides excellent control precision but significantly increases the overall production cost of the robot.
[Disclaimer] The content is sourced from the Motor Alliance. Copyright belongs to the original source. It is provided for reference only. If you believe your rights have been infringed, please contact the editor to have the content removed. For partnership opportunities or any questions, please leave a message via the backend.
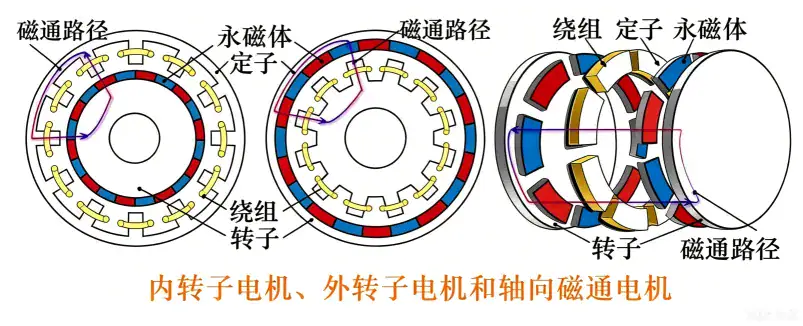
A multi-pole architecture brings a high-frequency fundamental; at 10,000 rpm the fundamental frequency can reach several kHz. Traditional IGBTs suffer soaring switching losses and severe heating — it is the MHz-class switching capability of SiC MOSFETs that truly matches high-frequency multi-pole axial flux motors.
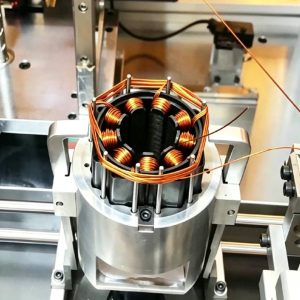
Jiuju Automation provides CNC motor winding machines and stator winding production lines suitable for brushless, servo, series-wound, and transformer coils, ensuring full slot fill and consistent turn-to-turn consistency.
 Jiuju Automation



 Español
 Français
 Deutsch (Sie)
 हिन्दी